Nonlinear Systems and Control Research Group
Nonlinear Systems and Control Research Group
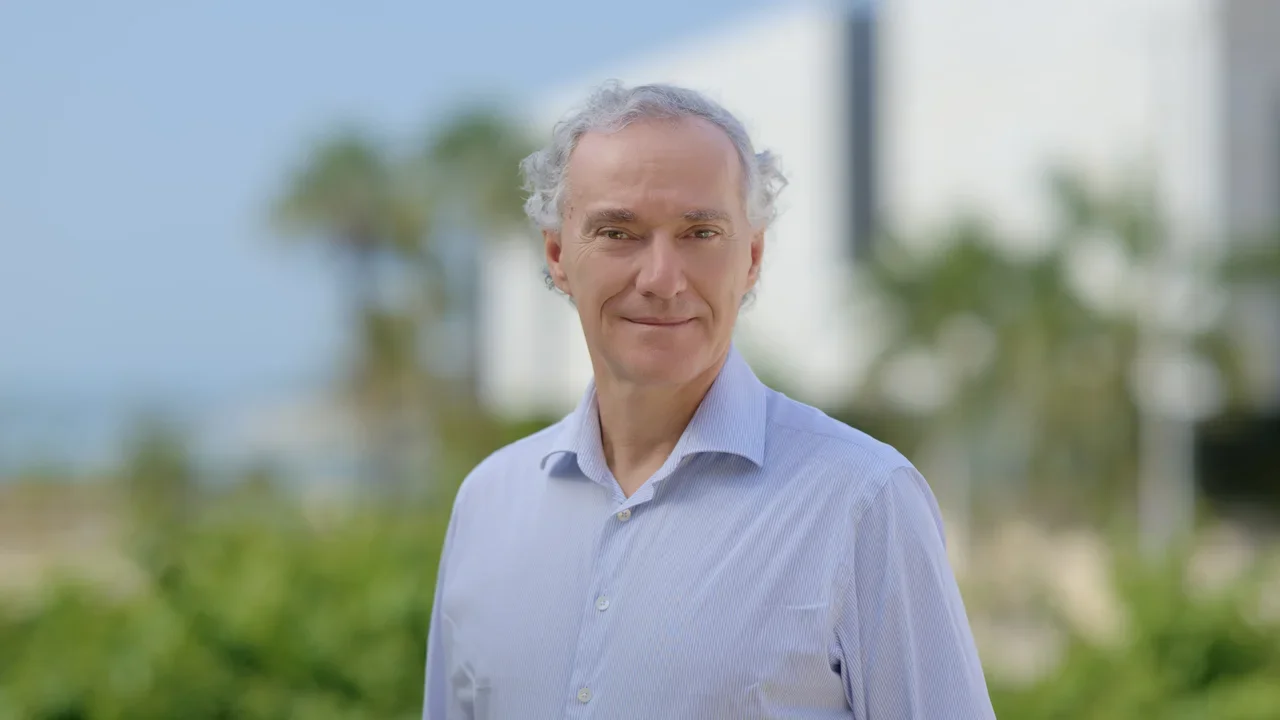
Professor Alessandro Astolfi leads the Nonlinear Systems and Control (NLSC) group
Research group areas of expertise and current scientific interests:
nonlinear, adaptive and robust control, learning-based control and estimation, model reduction, multi-agent systems, and autonomous systems
Our research group focuses on the analysis and design of nonlinear, adaptive, robust, and learning-based control and estimation methods, with emphasis on model reduction, multi-agent systems, game-theoretic methods, and autonomous systems. Applications span automotive, aerospace, power and energy, robotic, biomedical, and social systems.